
TIAGo as a social guide
A multimodal human-robot interaction system that lets a TIAGo robot guide visitors at a technology fair, with socially aware navigation and a dialogue engine with memory.
Details
- Period
- 2025 – 2026
- With
- Marco Turchetti, Filippo Tatafiore
- Status
- Completed
- Code
- Private repository
- Stack
- ROS 2, Nav2, Gazebo, MoveIt, Whisper, GPT-4o-mini
Case study
Problem
A robot guiding visitors at a crowded fair has to understand what people ask, move among them without invading their personal space, and make its intentions clear to people who have never used a robot.
System
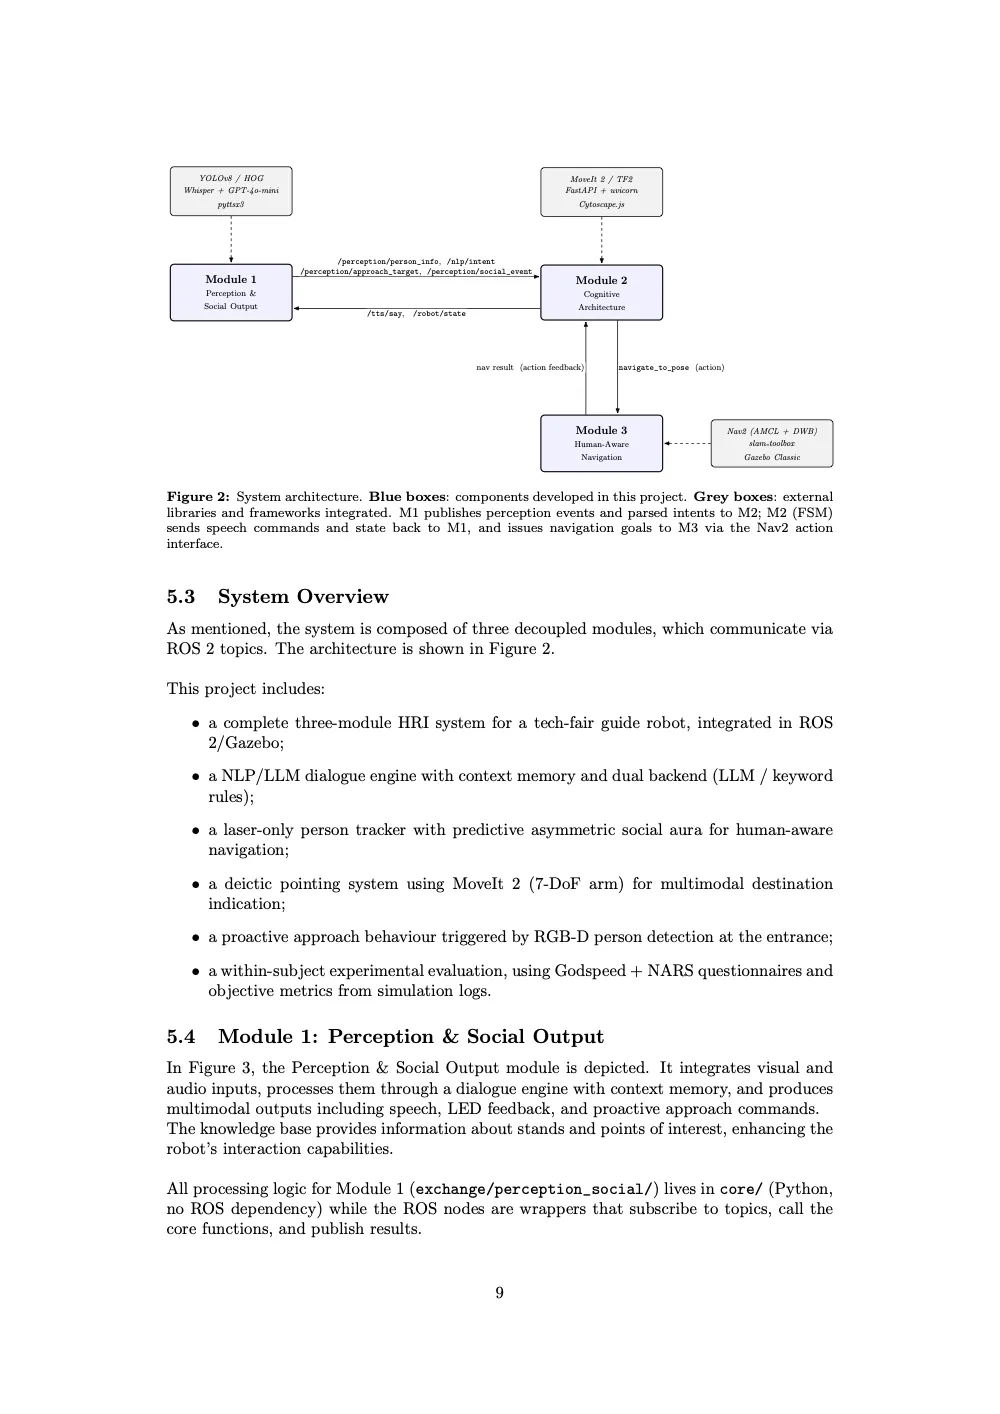
- Dialogue. Speech recognition with Whisper and a language-model dialogue engine with contextual memory, so the robot can follow up on earlier requests.
- Multimodal feedback. Speech, pointing gestures toward stands, and LEDs that show the robot’s internal state.
- Social navigation. Human-aware navigation that approaches visitors proactively and keeps out of their personal space.
- Environment. A custom Gazebo world of a 13 × 15 m technology fair.
Results
A within-subject study with 16 participants, in counterbalanced order, compared the social system with a baseline without social signals:
- Social navigation improved perceived safety by 0.86 points (Cohen’s d = 2.31), cut personal-space intrusions by 65% (from 5.94 to 2.06 on average) and shortened tasks by 5.5 seconds.
- Multimodal feedback improved how anthropomorphic, alive and likeable the robot was perceived.
- Dialogue memory improved perceived intelligence and the overall experience.
Team project with Marco Turchetti and Filippo Tatafiore, Sapienza University of Rome.